
Mu Huang, 黄沐
I am a Ph.D. student in Computer Science at Fudan University, advised by Bo Dai. I received my bachelor’s degree from Beijing Institute of Technology.
My research spans physics-based world modeling and embodied intelligence. I build world models through real-to-sim reconstruction and physics simulation, and explore WAM, VLA, and agent harness for robots.
🔥 News
- 2026.09: 🎉 We released InternW0-Δ, a world-action model combining causal imprint with 4D-aware representation.
- 2026.05: 🎉 SoMA was accepted to ICML 2026. We build a physically grounded world simulator for robotic soft-body manipulation.
- 2025.09: 🎉 Reversible GNS was released on arXiv. We study reversible graph simulators for consistent bidirectional modeling of dissipative fluids.
- 2025.06: 🎉 GausSim was accepted to ICCV 2025. We explore Gaussian-based simulation for forecasting elastic object dynamics.
- 2023.10: 🎉 PLSE was accepted to EMNLP 2023 as an oral presentation. We enhance discourse relation recognition with prompt-based logical semantics.
🔖 Technical Reports
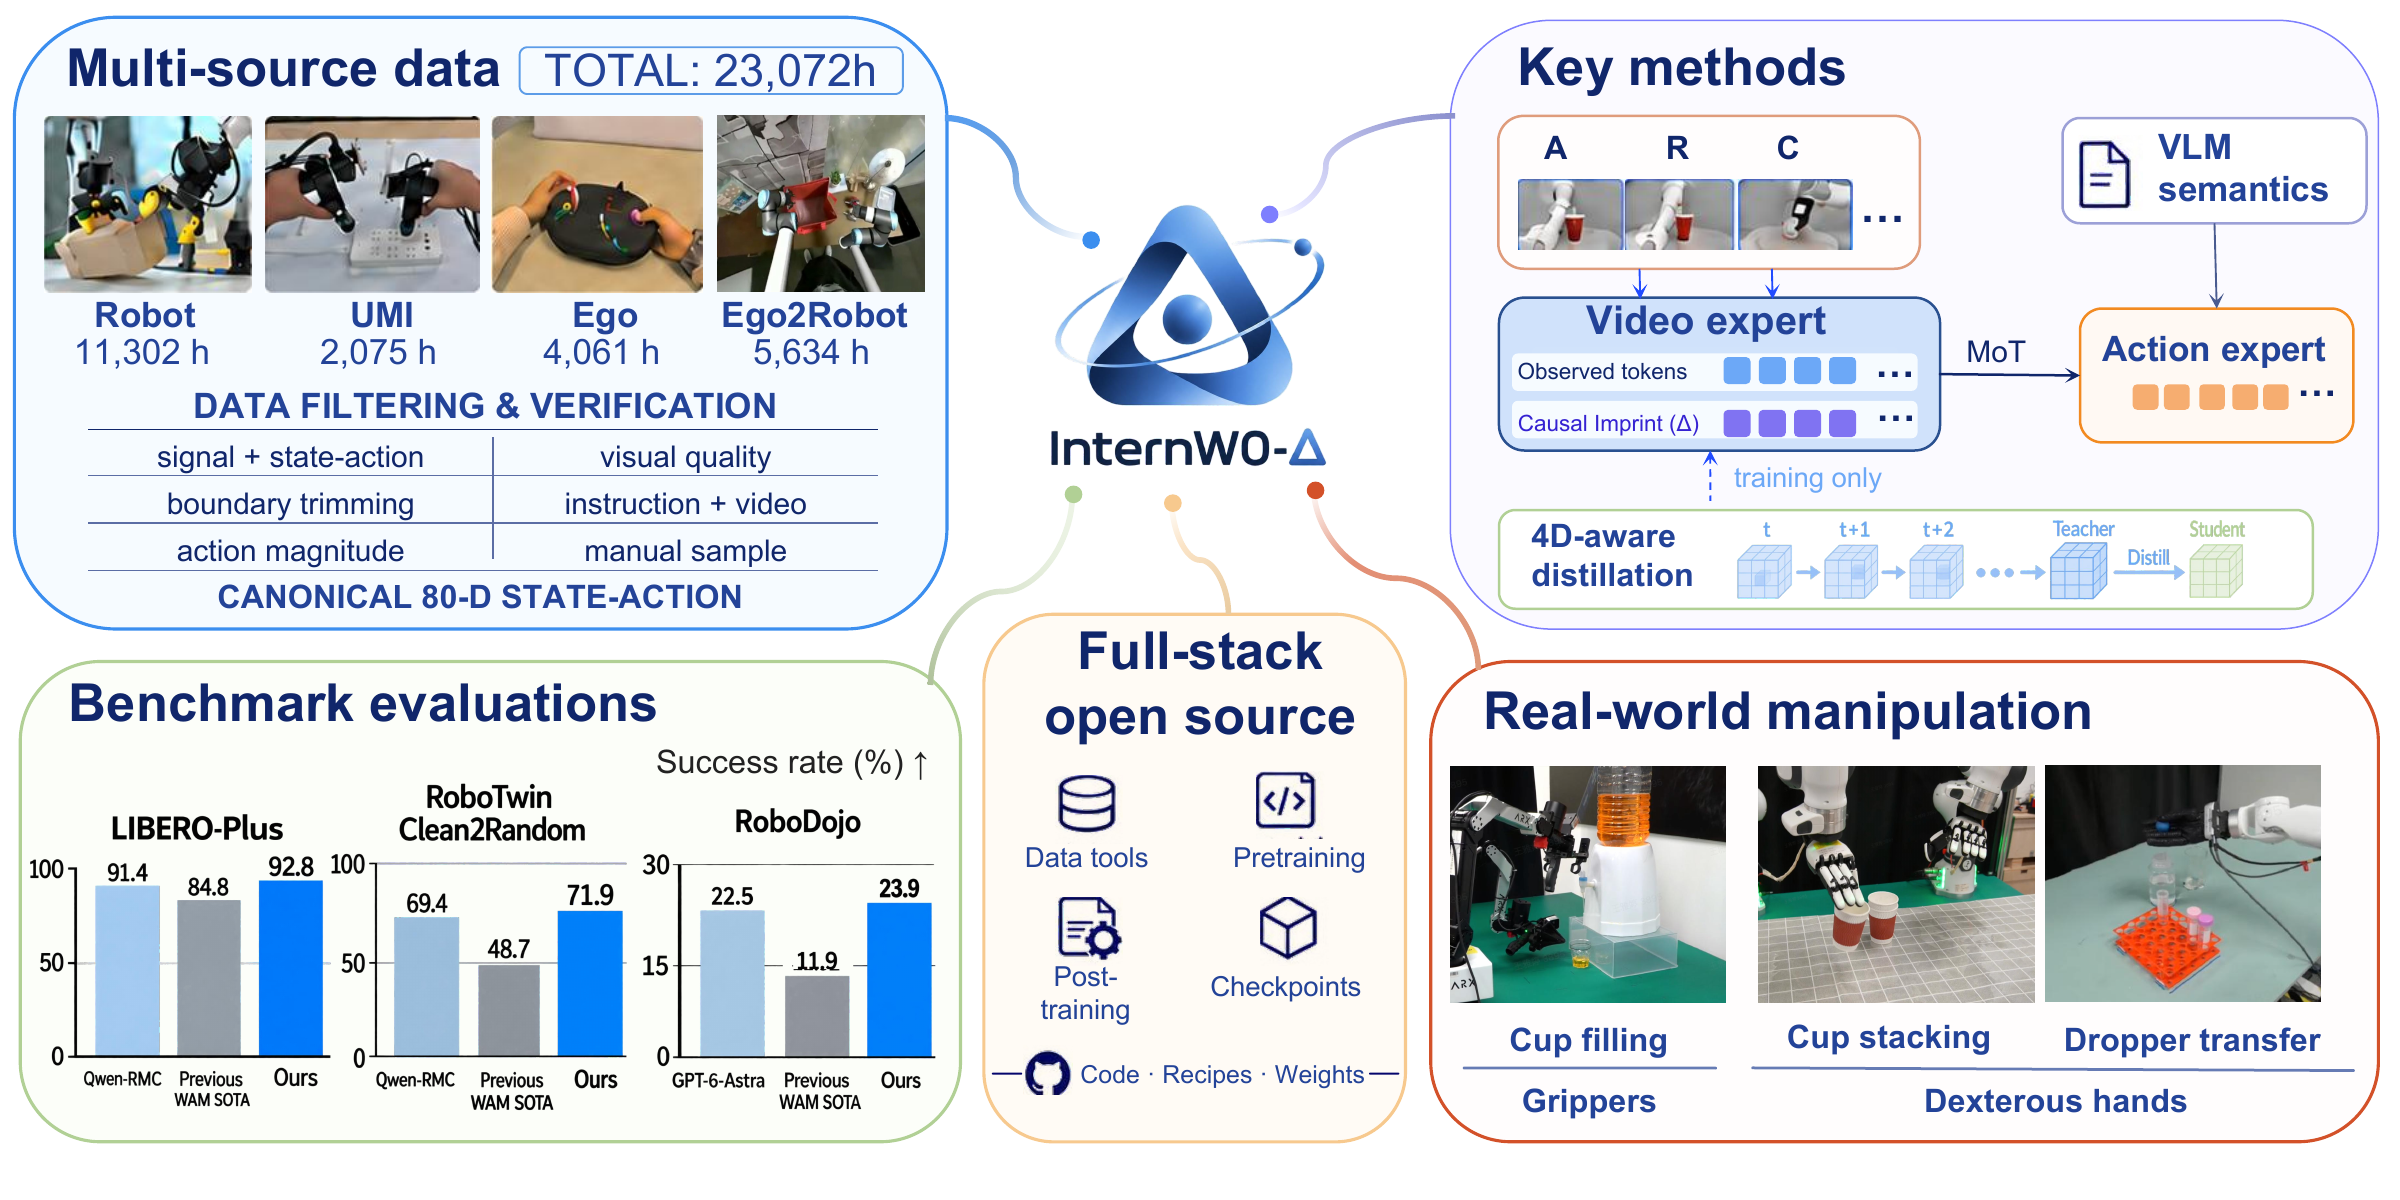
InternW0-Δ: A World Action Model Bridging Predictive Dynamics and Actions with 20K+ Hours of Open Data
Physical Intelligence Team · Contributed to post-training
[Blog] [Paper] [Code] [Hugging Face]
- A world-action model that jointly learns visual dynamics and robot actions, combining Causal Imprint with 4D-aware representation distillation for manipulation with grippers and dexterous hands.
📝 Research Papers

SoMA: A Real-to-Sim Neural Simulator for Robotic Soft-body Manipulation
Mu Huang, Hui Wang, Kerui Ren, Linning Xu, Yunsong Zhou, Mulin Yu, Bo Dai†, Jiangmiao Pang
[Paper] [Project Page] [Code]
- SoMA is a Gaussian-splat world simulator for real-world robotic soft-body manipulation, enabling action-conditioned, stable long-horizon simulation with multi-view-consistent rendering.

Reversible GNS for Dissipative Fluids with Consistent Bidirectional Dynamics
Mu Huang, Linning Xu, Minyue Dai, Yidi Shao, Bo Dai†
[Paper]
- We built a reversible (bidirectional) graph network simulator that unifies forward dynamics prediction and fast inverse inference within a unified framework for dissipative fluid systems.

GausSim: Foreseeing Reality by Gaussian Simulator for Elastic Objects
Yidi Shao, Mu Huang, Chen Change Loy, Bo Dai†
[Paper] [Project Page] [Code]
- GausSim models real-world elastic-object dynamics with Gaussian Splats and continuum-mechanics constraints for physically plausible forecasting.

Prompt-based Logical Semantics Enhancement for Implicit Discourse Relation Recognition
Chenxu Wang, Ping Jian†, Mu Huang
- PLSE injects discourse-relation knowledge into language models through prompt-based connective prediction and logical semantics enhancement.
🏅 Honors and Awards
- Chinese Physics Olympiad, First Prize in Hunan Province in 2018.
- National College Physics Competition in Some Regions of China, First Prize in Beijing in 2020.
- Outstanding Undergraduate Thesis at Beijing Institute of Technology in 2024.
- Outstanding Undergraduate at Beijing Institute of Technology in 2024.
- Excellence Student Scholarship, First Prize in Beijing Institute of Technology (Multiple).
- Ethnic Student Learning Award, First Prize in Beijing Institute of Technology (Multiple).
💬 Community Services
- Reviewer: ICML 2026, AAAI 2027, ICLR 2027.
💻 Internships

